About me
Hi, I am Sirui (Eric) Chen (陈思睿), a final-year CS PhD student at Stanford advised by Professor Karen Liu. I am interested in designing robot control and planning algorithms for contact-rich tasks such as dexterous manipulation and humanoid whole-body loco-manipulation. I also work on solving complex control problems on real robots by combining human demonstrations from different sources with analytical modeling.
I interned at Honda Research Institute in summer 2024, advised by Rana Soltani Zarrin; at NVIDIA GEAR Lab in summer and fall 2025, advised by Yuke Zhu and Zhengyi Luo; and at Amazon FAR in 2026, advised by Karen Liu and Guanya Shi.
In my free time, I enjoy photography and hiking; here are some photos I have taken. Feel free to reach out about full-time opportunities or to discuss research ideas.
Selected research
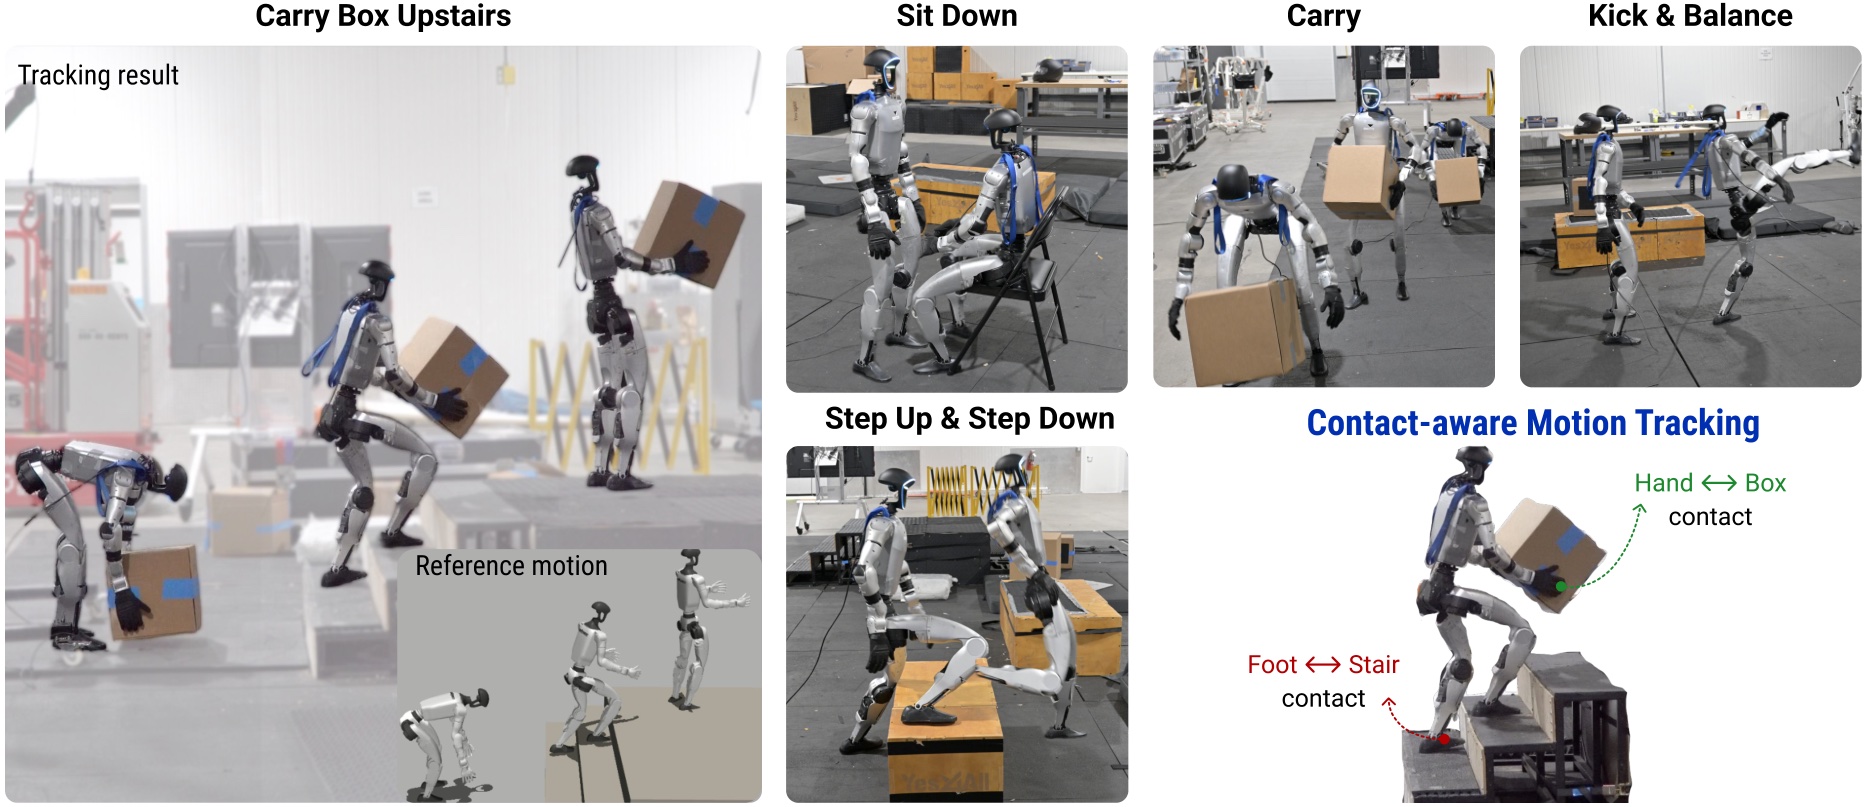
SceneBot: Contact-Prompted General Humanoid Whole Body Tracking with Scene-Interaction
Arxiv, 2026
A unified contact-conditioned humanoid tracker for free-space motion, terrain, and object interaction
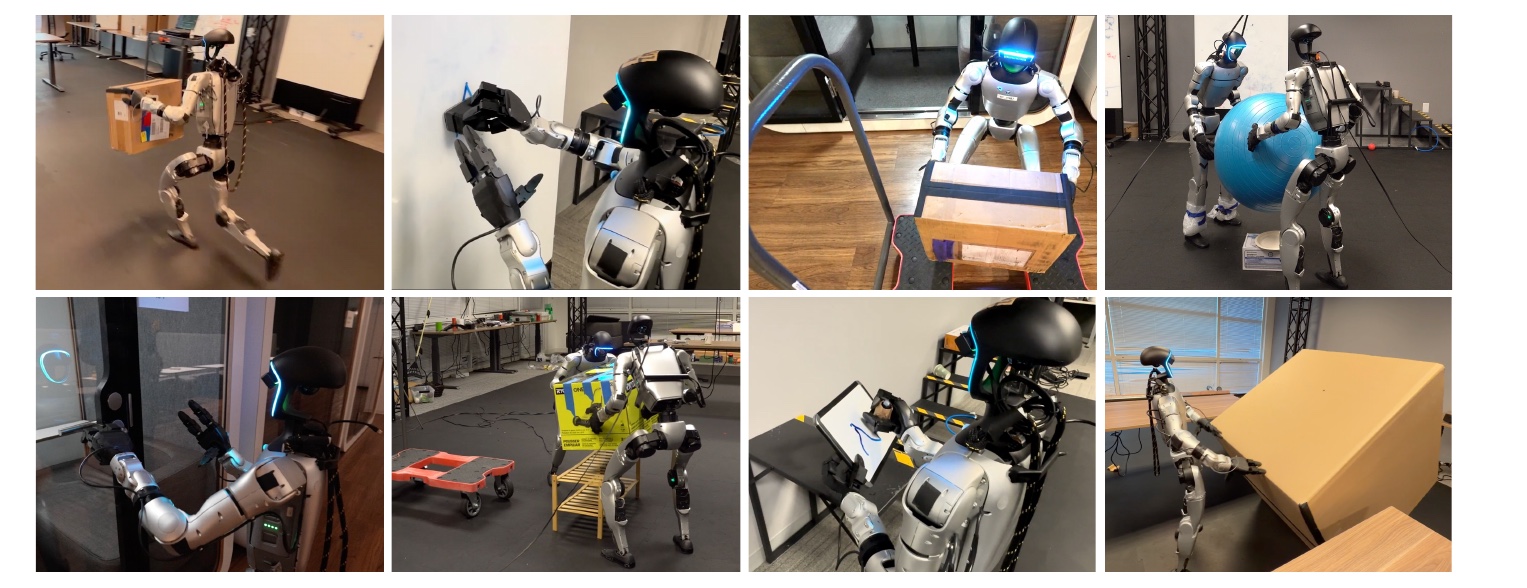
CHIP: Adaptive Compliance for Humanoid Control through Hindsight Perturbation
Conference on Robot Learning, 2026
A plug-and-play module for controllable humanoid end-effector compliance
SONIC: Supersizing Motion Tracking for Natural Humanoid Whole-Body Control
Science Robotics, 2026
Scaling up humanoid robot control via motion tracking