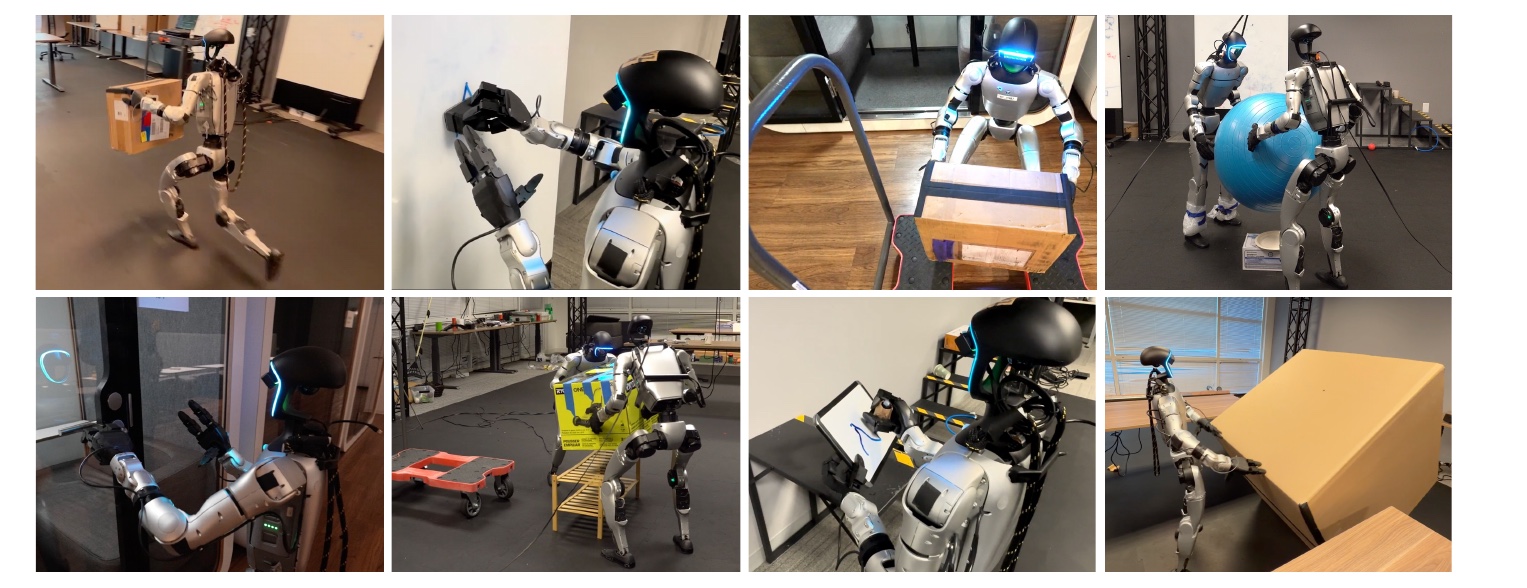
CHIP: Adaptive Compliance for Humanoid Control through Hindsight Perturbation
Published in Conference on Robot Learning, 2026
Recommended citation: S. Chen, Z. Cao, Z. Luo, F. Castaneda, C. Li, T. Wang, Y. Yuan, L. Fan, C.K. Liu, Y. Zhu. (2026). "CHIP: Adaptive Compliance for Humanoid Control through Hindsight Perturbation." CoRL. https://arxiv.org/abs/2512.14689
Abstract
Recent progress in humanoid robots has unlocked agile locomotion skills, including backflipping, running, and crawling. Yet it remains challenging for a humanoid robot to perform forceful manipulation tasks such as moving objects, wiping, and pushing a cart. We propose adaptive Compliance Humanoid control through hIsight Perturbation (CHIP), a plug-and-play module that enables controllable end-effector stiffness while preserving agile tracking of dynamic reference motions. CHIP is easy to implement and requires neither data augmentation nor additional reward tuning. We show that a generalist motion-tracking controller trained with CHIP can perform a diverse set of forceful manipulation tasks that require different end-effector compliance, such as multi-robot collaboration, wiping, box delivery, and door opening.